Zhejiang University · Computer Science
Junhan Sun 孙俊涵
I am a first-year Ph.D. student at Zhejiang University, working with Prof. Guofeng Zhang at Zhejiang University and Prof. Hao Zhao at Tsinghua University.
My research connects predictive representations, world models, and embodied control. I am interested in how learned models turn visual goals into efficient, purposeful action.
Previously: Chu Kochen Honors College, Zhejiang University.
RepresentationIntentAction · Learning the world to act in it.
Explore INTACTPublications
Public preprints · * Equal contribution
arXiv preprint · 2026
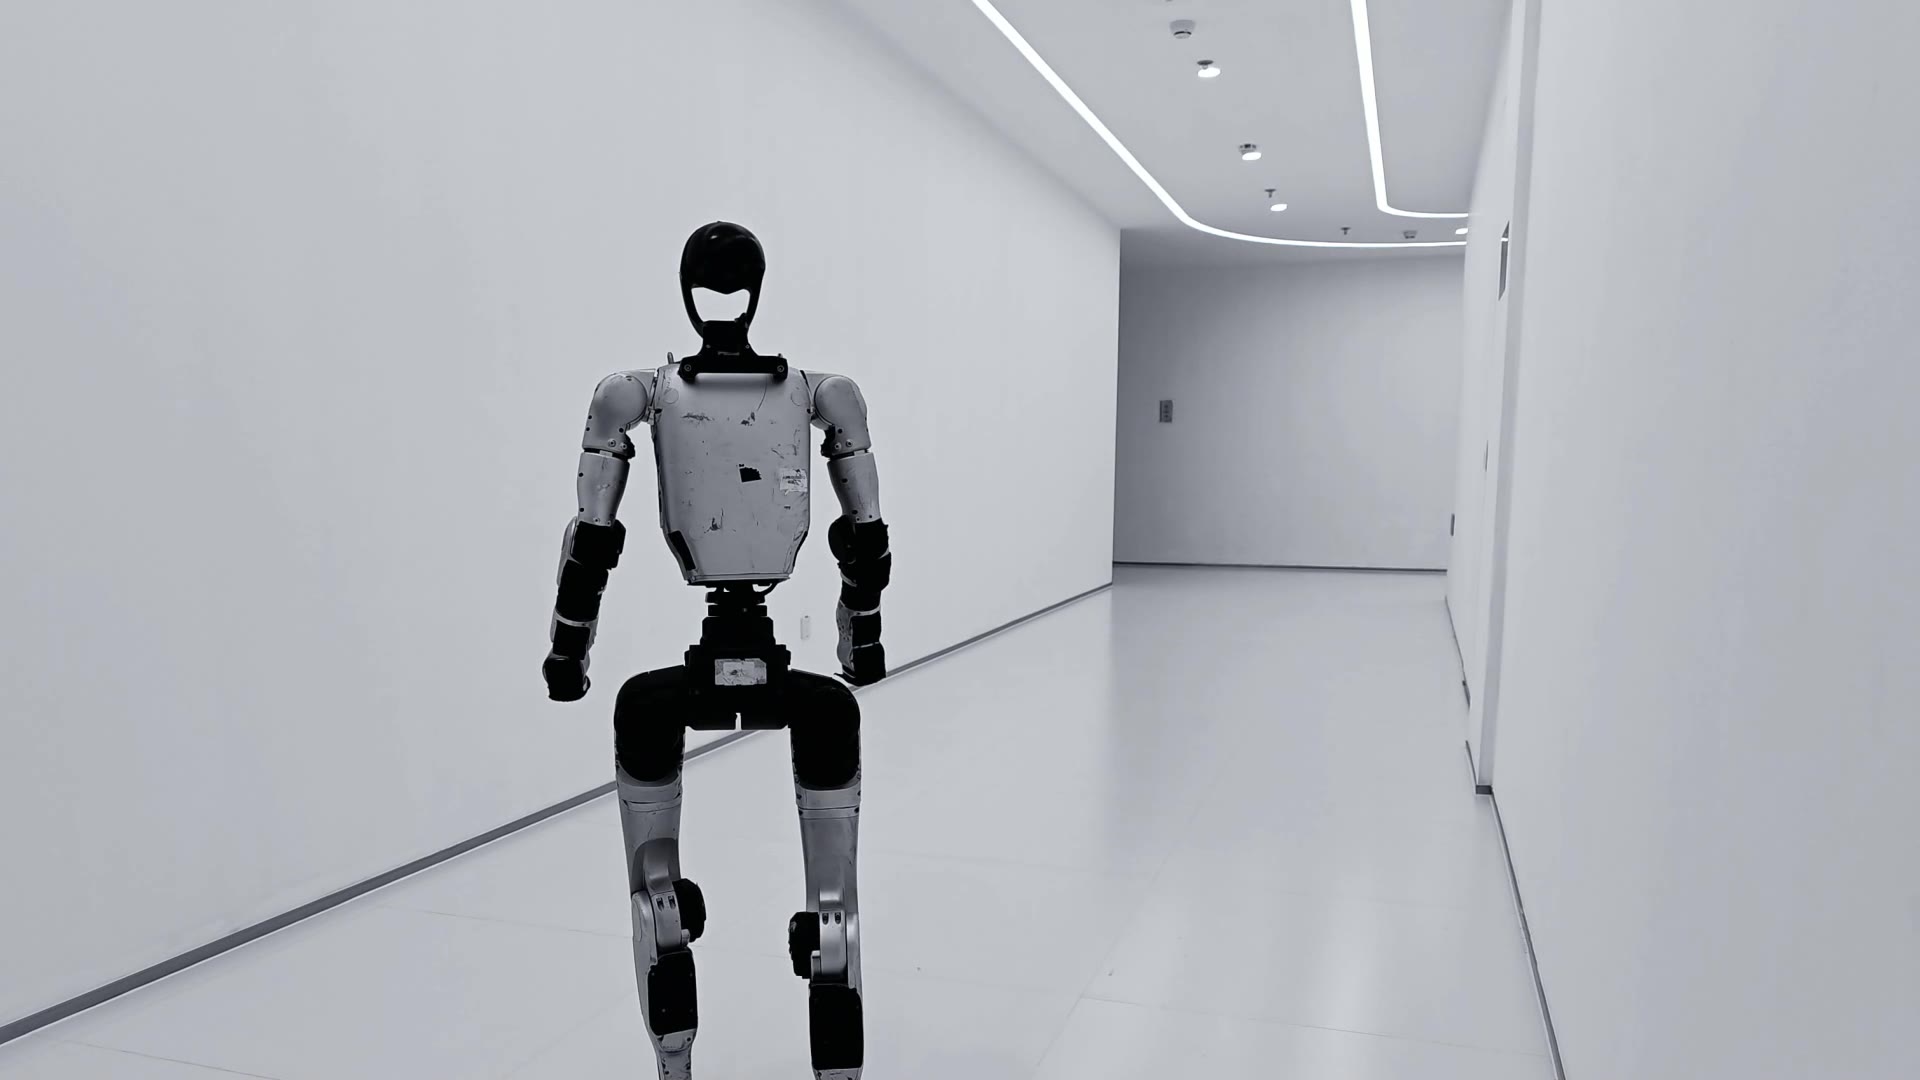
PredActor: Predictive Action Diffusion for Steerable Onboard Humanoid Control
arXiv preprint · 2026
INTACT: Isomorphic Intent-to-Action Learning for Search-Free World Models
arXiv preprint · 2026
LAMP: Lift Image-Editing as General 3D Priors for Open-world Manipulation
Software
CLEAR-LeWMCommunity evaluation software
An auditable evaluation suite for LeWM-compatible latent world models, with official-compatible and difficulty-controlled task protocols.
Updates
I-BFM is now a public preprint.
New preprints: FlexiWorld and PredActor.
Released INTACT code, evaluation stack, and model artifacts.
Earlier updates
Released the INTACT preprint and project page.
Open-sourced CLEAR-LeWM for world-model evaluation.
Education
2026 — Present
Ph.D. in Computer Science
Zhejiang University · College of Computer Science and Technology
State Key Laboratory of CAD&CG
2022 — 2026
Undergraduate study
Chu Kochen Honors College, Zhejiang University
Contact
I welcome conversations about world models, representation learning, and robot learning.